

Introduction — a short scene, a number, and a question
I was in my garage one rainy afternoon, hunched over a stubborn fan that wouldn’t spin, and it took me back to the first motor I ever rewound. Back then I learned that an electric motor can be as simple as a coil and a bit of curiosity, yet today many designs hide new tricks (and old traps). Recent industry data shows that small- and medium-sized plants report up to 18% of downtime tied to motor-related control issues — surprising for something so basic. So I ask: why do we still chase symptoms instead of fixing the root cause?
I’ve been around machines long enough to see patterns—some clear as the stator’s winding, others buried in paperwork. I’ll share what I’ve picked up: practical notes, a few regrets, and a couple of quick wins you can use tomorrow. Let’s move from a soaked fan on my bench to the nuts and bolts that make motors run right. Next up: where the usual fixes fail and what users quietly suffer through.
Where typical fixes fall short (and what users quietly endure)
electric motors are often treated like black boxes: swap a part, hope it behaves. That shortcut fails when the issue is systemic — mismatched drives, poor thermal paths, or flawed sensor inputs. I’ve seen controllers push current beyond safe limits because the system tuned only for peak speed, not for sustained torque. The result? Repeated failures and frustrated maintenance crews. Look, it’s simpler than you think: neglecting system-level checks wastes time and money.
Why does this keep happening?
Two common faults I keep encountering: inadequate feedback (bad or missing encoders) and improper power converters sizing. Those faults don’t shout; they whisper. Users feel heat spikes, longer spin-up times, and weird vibrations, then patch with resets. I’ve sat through more than a few meetings where we blamed the motor when the real culprit was the drive settings. — funny how that works, right?
New principles to guide better designs — and a practical outlook
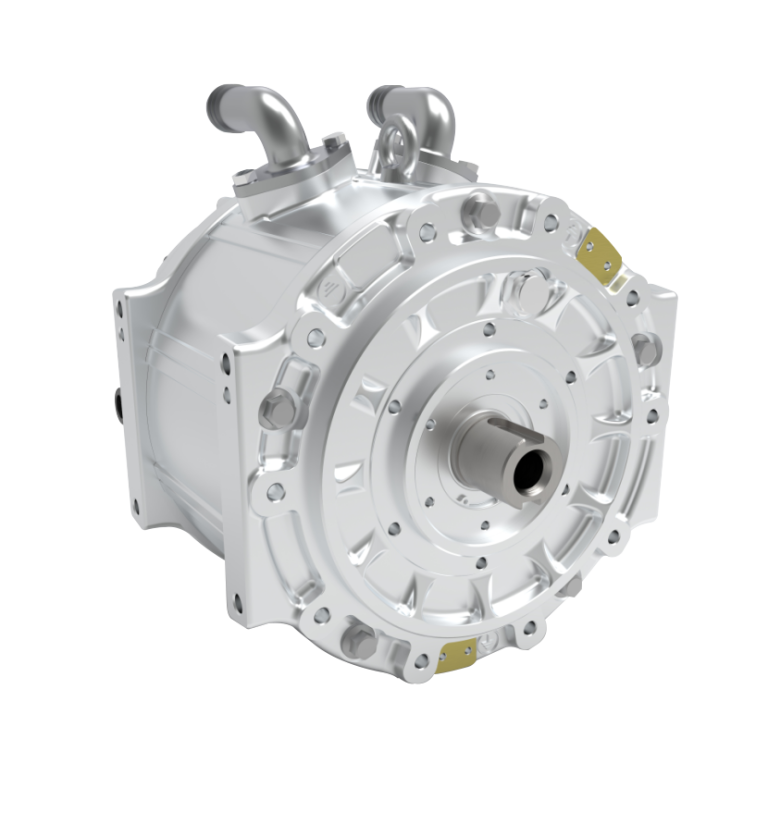
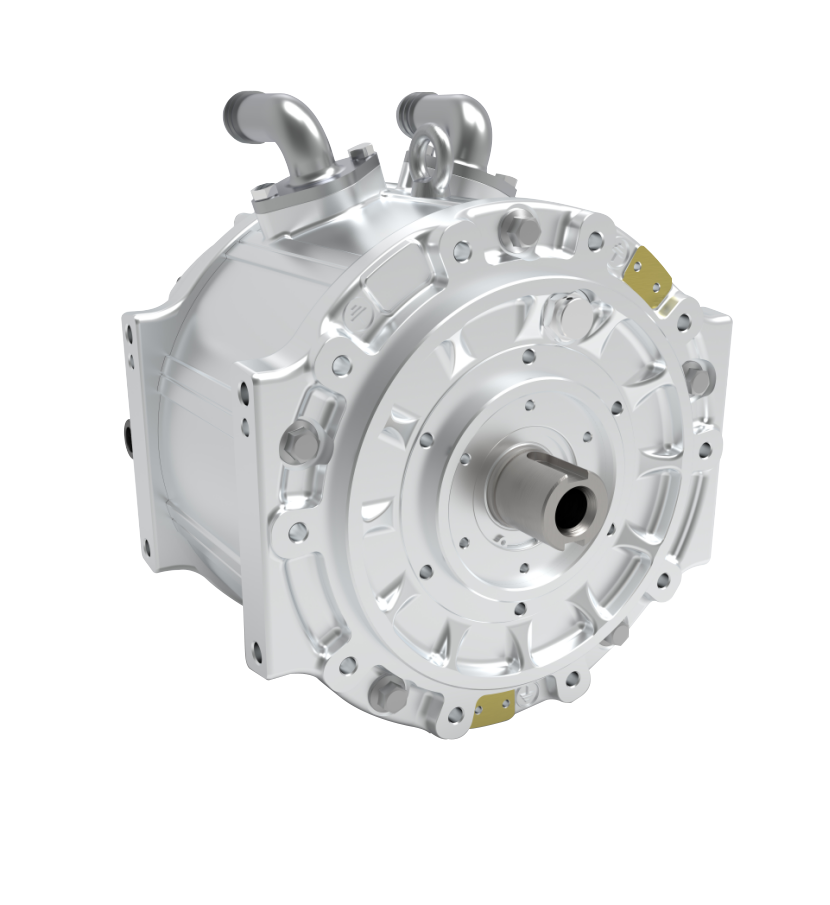
We now have better tools to address those system flaws: model-based tuning, sensor fusion, and smarter PWM schemes. When I explain new technology principles, I like to start plain: the motor, the drive, and the control loop must be designed together. For example, with a modern pmsm motor you can tighten control loops and extract more torque per amp — but only if the inverter, thermal path, and rotor magnetic design are considered as one. I’ve watched modest changes in control logic cut energy use and extend bearing life. — I still shake my head at how often that step is skipped.
What’s Next for technicians and designers?
Think modular design and digital twins. Use condition monitoring to catch trends before they become failures. Pair that with predictable thermal models and you get systems that behave — not occasionally, but consistently. Here are three quick metrics I now use when evaluating upgrades: efficiency across the full load curve, thermal margin at rated torque, and control-loop latency under transient loads. If a proposal scores poorly on any of these, I dig deeper. Choosing the right components and settings matters. Real-world gains are measurable: lower downtime, fewer replacements, and calmer crews.
In the end, we don’t chase flashy specs — we look for reliable performance. I’ve learned to favor thoughtful system checks over band-aid fixes. If you want solid motors that keep shops humming, start with those three metrics and insist on integrated testing. For ready solutions and practical parts, I often point colleagues to suppliers who stand behind their work — like Santroll.